SYSAL / IMPERIAL COLLEGE LONDONRESEARCH LABORATORY
SYSTEMS & ALGORITHMS LABORATORY
Designing trustworthy
autonomous systems.
Learning, control and decision-making for the physical world.
We develop algorithms and engineered systems that connect learning, decision-making and the physical world. Our research spans trustworthy autonomy, planning under uncertainty, intelligent communications, digital fabrication and privacy-preserving sensing.
01 / FEATURED RESEARCHIEEE TASE 2025 · IROS 2025 PRESENTATION
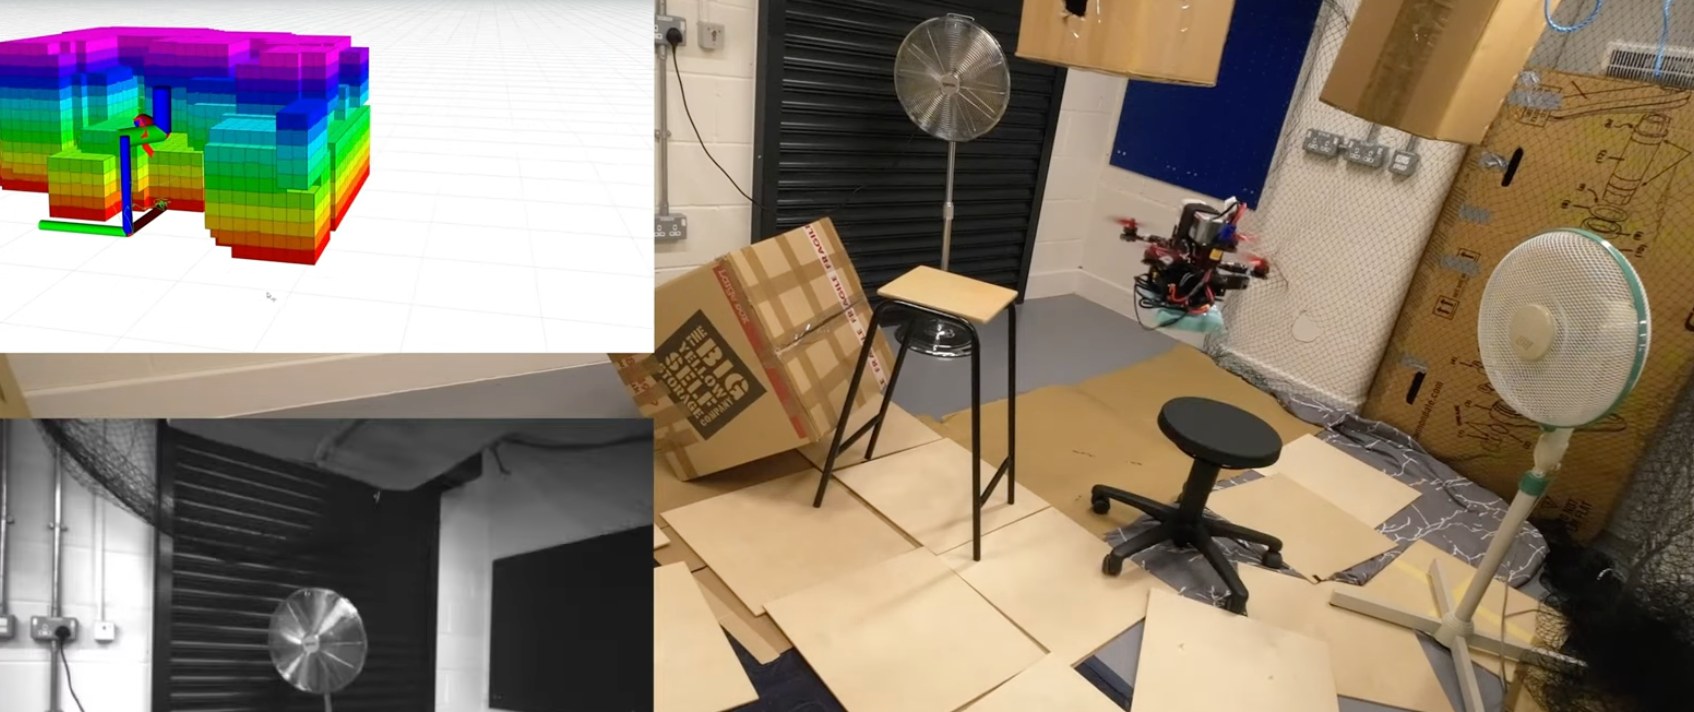
ConsDRED flight demonstration · Wang & Boyle · IEEE TASE 2025
Reliable quadrotor control under uncertain aerodynamic forces ↗
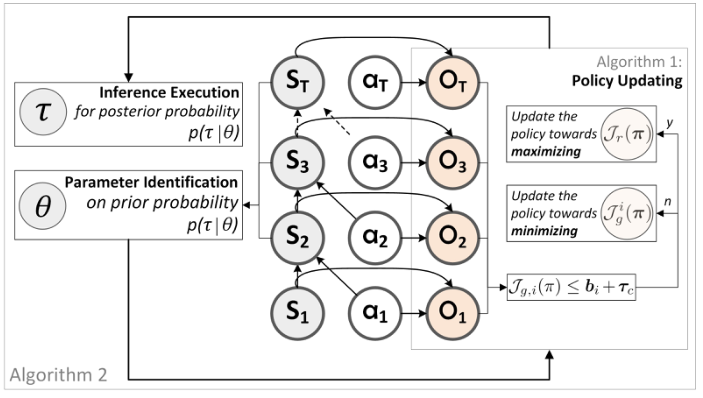
ConsDRED combines distributional reinforcement learning with stochastic model predictive control to track trajectories while respecting constraints.
MISSION PLANNING / OPTIMISATION
Planning under uncertainty
Mission-level routing, resource allocation and adaptive replanning as operating conditions change.
Research in European Journal of Operational Research and IEEE Internet of Things Journal.
Explore planning research ↗ LEARNING / WIRELESS COMMUNICATIONS
Learning for intelligent communications
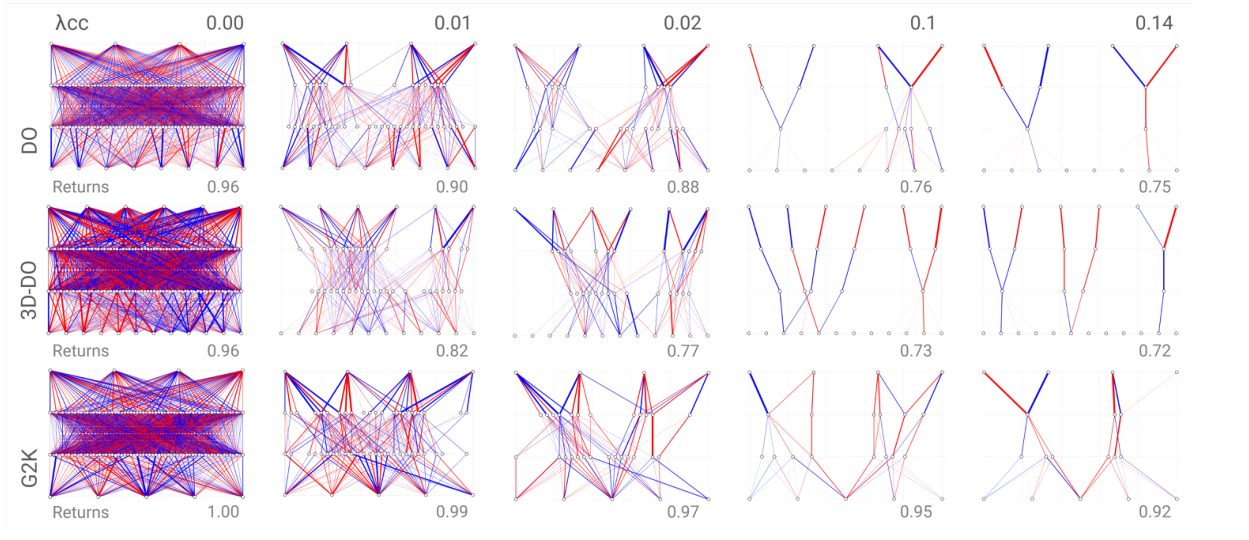
Multi-agent learning, aerial networks and reconfigurable wireless systems, with an emphasis on performance, fairness and explainability.
Research in IEEE TMLCN, Ad Hoc Networks and IEEE OJ-COMS.
Explore communications research ↗ 3D-PRINTED ELECTRONICS / DIGITAL FABRICATION
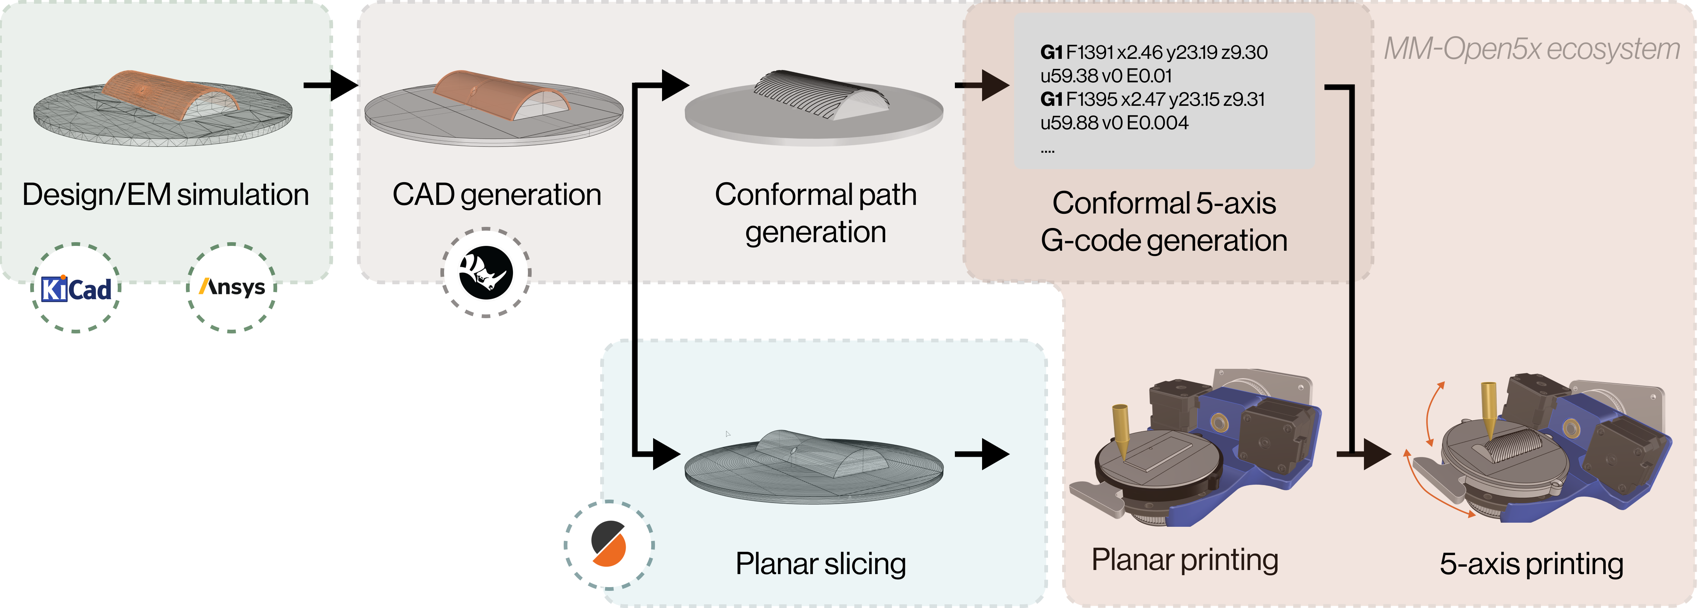
3D-printed electronics and digital fabrication
Designing and fabricating functional electronics on curved and freeform surfaces—from thermoformed circuits to conformal antennas and multi-layer power electronics. Open5x and MM-Open5x provide open platforms for multi-axis, multi-material printing.
Explore fabrication research ↗ PRIVACY / TRUSTWORTHY SENSING
Towards private and trustworthy sensing
Understanding and limiting unintended inference from sensor data, including paralinguistic information carried by speech.
Research published in ACM TOPS, Interspeech and CCW.
Explore sensing research ↗