RESEARCH / IEEE TASE 2025
ConsDRED
Constrained reinforcement learning using distributional representation for trustworthy quadrotor UAV tracking control.
Tracking under uncertainty
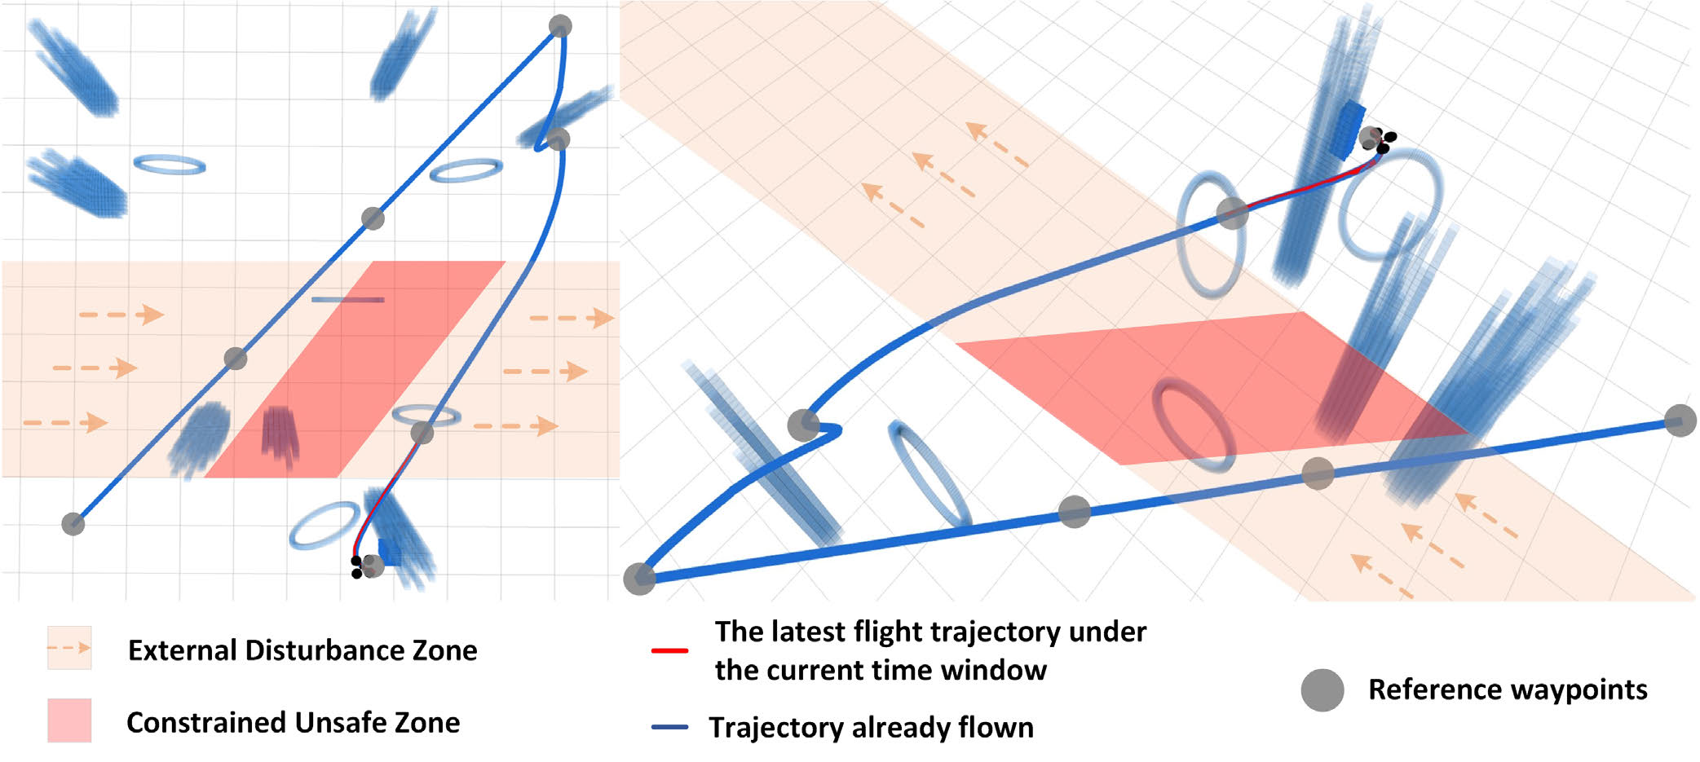
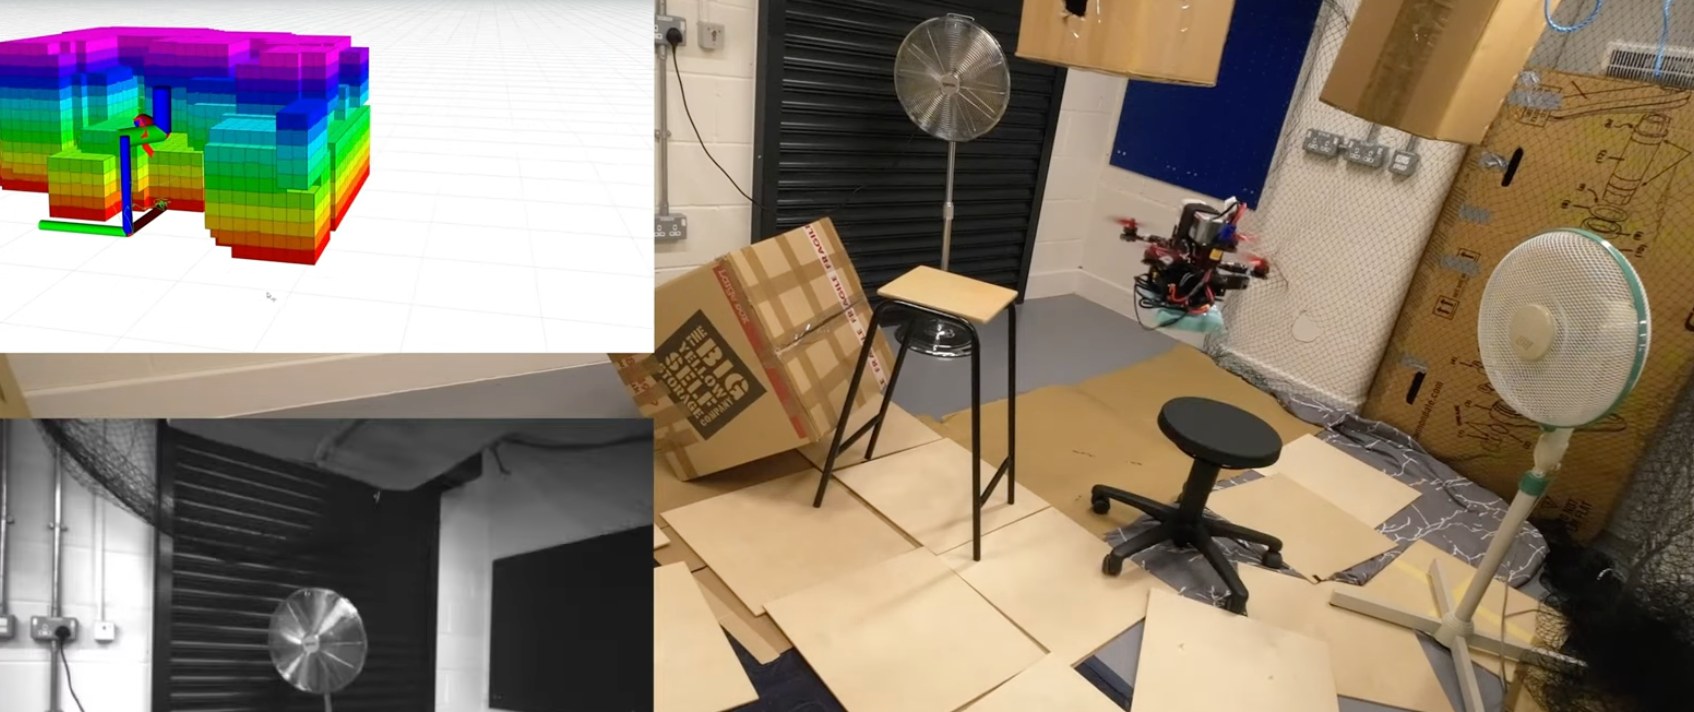
ConsDRED combines a distributional reinforcement-learning disturbance estimator with stochastic model predictive control, addressing uncertain aerodynamic effects and constrained trajectory tracking.
Yanran Wang and David Boyle · IEEE Transactions on Automation Science and Engineering, volume 22, pages 5877–5894 (2025). Also presented at IROS 2025.